From human dexterity to humanoid robotics: Building smarter robotic hands with system simulation
Recent advances in artificial intelligence, perception, and locomotion have enabled humanoid robots to walk, navigate, and understand their environment more effectively than ever before.
But there is a critical reality: A humanoid robot creates value only when it can interact with the physical world. That means grasping objects, turning a valve, or operating a tool. These seemingly simple operations rely on one of the most complex systems in engineering: the robotic hand.
Designing a robotic hand requires balancing dexterity, gripping force, compactness, battery autonomy, thermal performance, reliability, weight, and cost, all at the same time. This is precisely where System Simulation with Simcenter Amesim becomes a game-changing technology.
The human hand: nature’s most sophisticated manipulator
Before understanding the challenges of robotic hands, it is worth appreciating the extraordinary system engineers are trying to replicate.
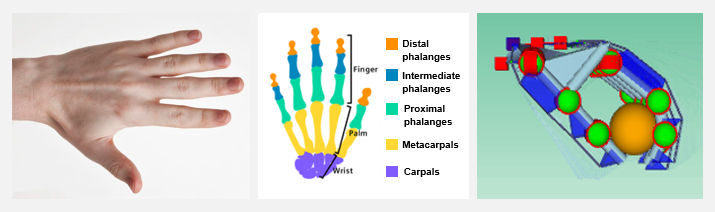
The human hand is often considered one of the most sophisticated biomechanical systems ever evolved. With 27 bones, more than 30 muscles, numerous tendons, ligaments, joints, and thousands of sensory receptors, it can perform an astonishing range of tasks, from lifting a heavy suitcase to threading a needle.
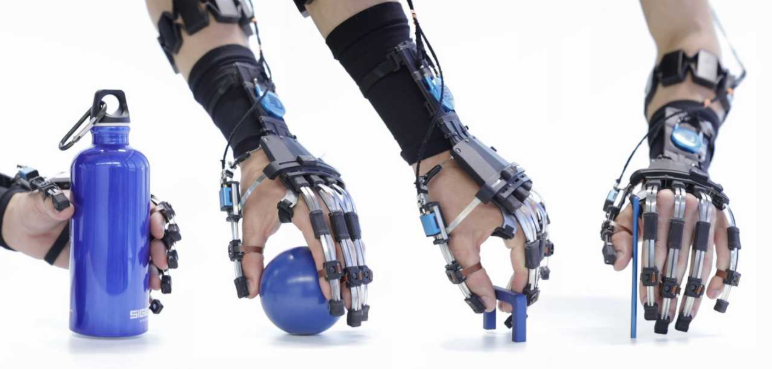
What makes the human hand remarkable is not simply its dexterity, but its ability to continuously balance competing requirements: high force generation, fine precision, fast response, energy efficiency, durability, adaptability, and compactness.
Most of the muscles responsible for finger motion are not even located in the hand itself. Instead, they are located in the forearm and transmit forces through tendons running into the fingers. This biological architecture reduces the mass of the fingers, enabling rapid movements while maintaining significant gripping force.
Interestingly, many modern humanoid robotic hands use exactly the same principle. Engineers place electric motors in the forearm and transmit forces through cables, ropes, or Bowden mechanisms, mimicking the way biological muscles actuate human fingers. However, recreating a biological system remains enormously challenging.
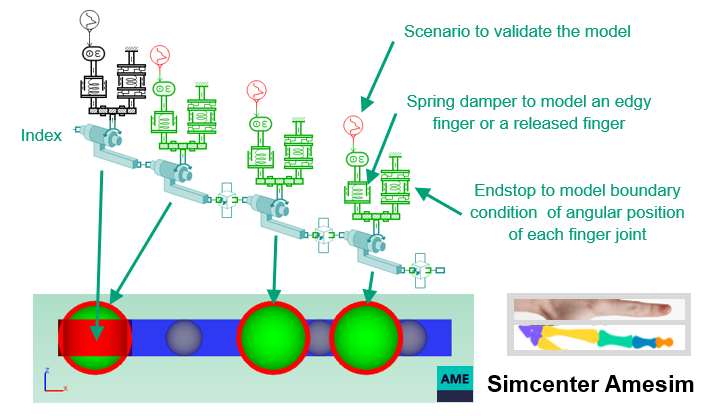
While a human hand effortlessly performs millions of coordinated movements each day, humanoid robots must achieve similar performance using electric motors, gearboxes, ropes, sensors, power electronics, batteries and software controllers. Each subsystem introduces its own limitations, many of which interact in unexpected ways. This is precisely where system simulation becomes invaluable.
Why human hands are still better than robots
Despite recent breakthroughs in humanoid robotics, human hands still outperform robotic hands in several important areas.
Natural compliance
Human fingers naturally adapt to object shapes through soft tissues, tendons, and muscle control. When picking up a delicate glass, humans instinctively apply only the required force.
Robotic hands often struggle with this challenge. Too little force causes slipping. Too much force risks damaging the object.
Simulation allows engineers to evaluate compliance mechanisms, tendon elasticity, and control strategies before implementing them in hardware.
Exceptional energy efficiency
The human hand can work for hours with minimal energy consumption. A humanoid robot performing similar repetitive tasks may consume significantly more electrical power due to actuator inefficiencies and control requirements.
Understanding these losses requires modeling the complete energy chain from battery to motor to transmission to fingertip.
Integrated sensing and control
Humans continuously use visual, tactile, and proprioceptive feedback to adapt their grip forces.
Robotic systems attempt to recreate these capabilities through force sensors, torque sensors, vision systems, AI algorithms and motion controllers. The challenge is not only creating the sensors but ensuring the entire system responds appropriately under real operating conditions.
The robotic hand is a complete system
One of the most common mistakes in robotic hand development is treating each subsystem independently.
- Mechanical engineers optimize tendon mechanisms.
- Electrical engineers size motors.
- Battery specialists focus on energy management.
- Control engineers tune algorithms.
- Thermal experts analyze cooling.
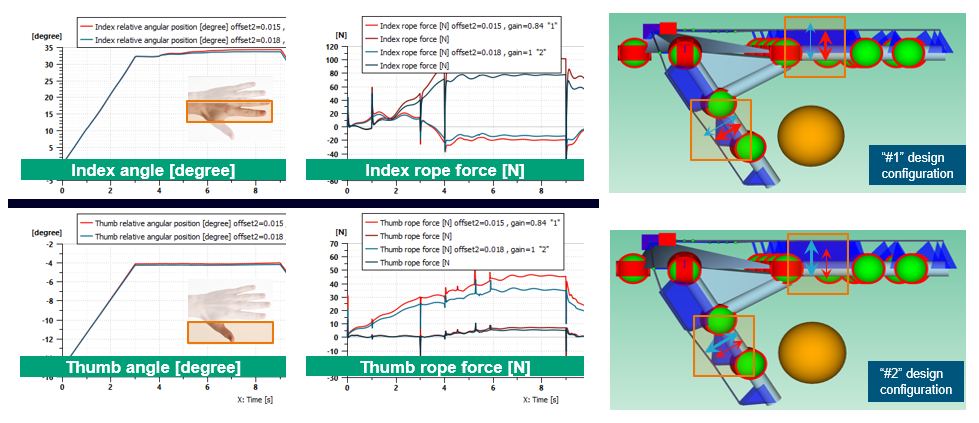
Yet every design decision affects every other subsystem. For example, a larger motor may provide increased gripping force. However, it also increases mass, consumes more power, generates additional heat, requires larger batteries and finally reduces autonomy.
Similarly reducing finger size may improve dexterity. But it also limits actuator packaging space, increases thermal challenges, increases tendon routing complexity.
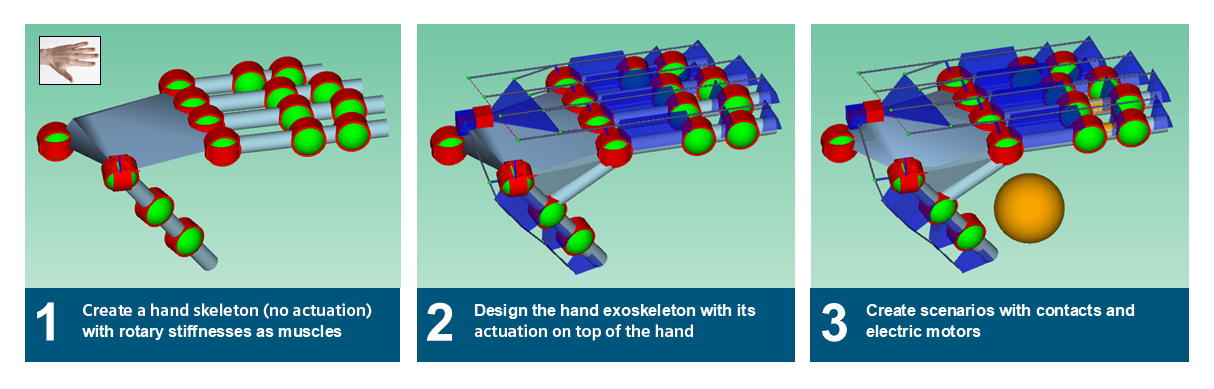
The robotic hand is therefore not merely a mechanical device. It is a multi-domain system. The only practical way to understand all these interactions simultaneously is through system simulation. Using Simcenter Amesim, engineers can create a complete digital twin of a robotic hand before any prototype exists.
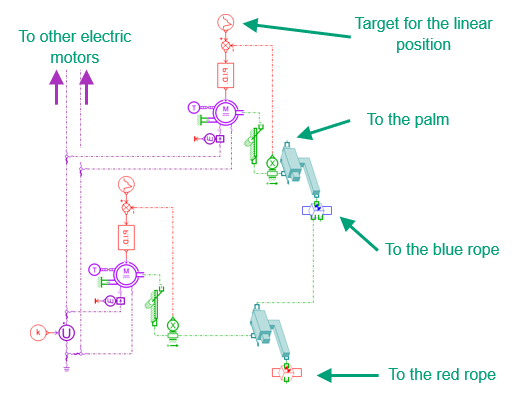
The methodology combines the ropes, actuators, electric motors, controls, friction phenomena and power requirements simulated within a single model. Instead of discovering issues during prototype testing, engineers can discover them during concept development.
Understanding tendons, ropes and friction
Many of today’s most advanced humanoid hands adopt tendon-driven architectures inspired by the human body. Motors are positioned in the palm or forearm while tendons transfer force to the fingers. This improves dexterity and reduces finger mass. However, it introduces a significant challenge: friction.
Every ring, pulley and cable guide creates losses. These losses directly impact the gripping force, motor sizing, battery consumption, thermal load and component durability.
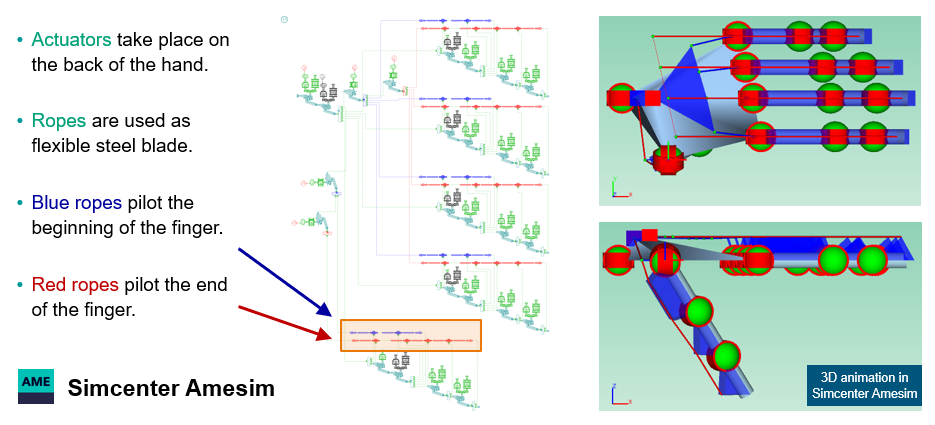
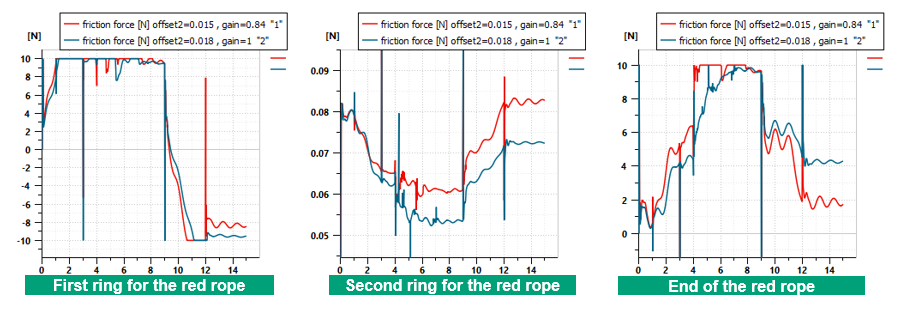
The digital twin developed with Simcenter Amesim demonstrated how friction can become one of the dominant factors within a tendon-driven system and identified exactly where force losses occur.
Instead of relying on assumptions, engineers can quantify these effects and optimize tendon architectures long before hardware is manufactured.
Sizing motors right the first time, optimizing battery autonomy
Motor selection is one of the most critical decisions in robotic hand development. Oversized motors increase weight, cost, battery requirements and thermal constraints. Undersized motors limit gripping force, payload capacity and reliability
Simulation allows engineers to size motors based on actual operational scenarios rather than conservative assumptions. The result is a design that achieves the intended performance with the minimum possible weight and energy consumption.
Industrial users do not buy humanoid robots because they have impressive specifications. They buy them because they can perform useful work. Autonomy therefore becomes a key performance indicator. Simcenter Amesim allows engineers to predict battery state-of-charge throughout realistic operating cycles.
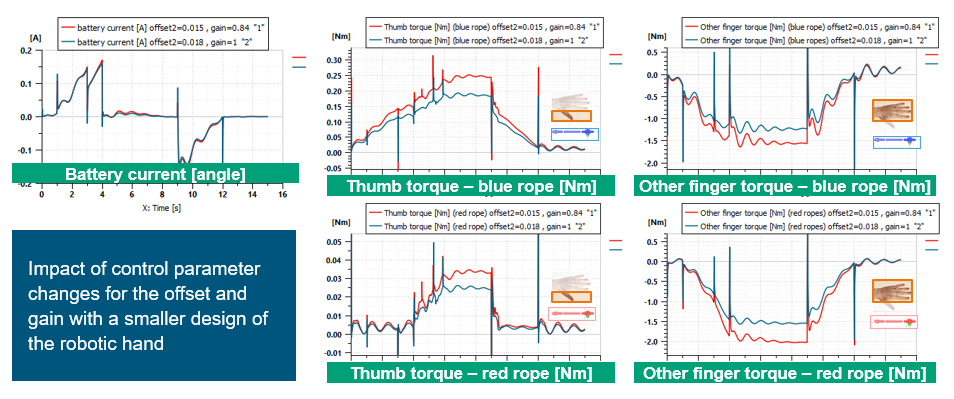
Questions such as:
- What is the impact of a more powerful motor?
- How many objects can be moved per shift?
- Can it grasp objects with complex or non-uniform shapes?
- Can it operate all usual hand manipulations (tripod pinch, cylindrical grip, hook, …)?
- How many valve opening/closing operations can be completed?
can be answered before any hardware investment is made.
Managing heat in compact robotic hands
As robotic hands become more compact and powerful, thermal management becomes a critical design constraint. Electric motors, electronics and transmissions continuously generate heat in confined volumes. Without proper management, the efficiency decreases, the reliability is reduced and the component lifetime shortens.
System simulation allows engineers to investigate not only the source of heat generation, but also how design choices influence thermal performance. The true power of Simcenter Amesim is that it shifts engineering decisions from component optimization to mission optimization.
Instead of asking: “How does this motor perform?”, engineers can ask: “Can this robotic hand successfully pull a cart for an entire shift?”. Instead of asking: “What is the friction coefficient of this tendon?”, they can ask: “Can this hand reliably manipulate thousands of objects per day?”
This system-level perspective dramatically accelerates development while reducing technical risk.
Why Simcenter Amesim matters for humanoid robotic hands
The race to deploy humanoid robots is accelerating. The companies that succeed will not necessarily be those with the most powerful AI or the fastest robot.
They will be those capable of delivering reliable, energy-efficient, cost-effective, and highly dexterous robotic systems that work day after day.
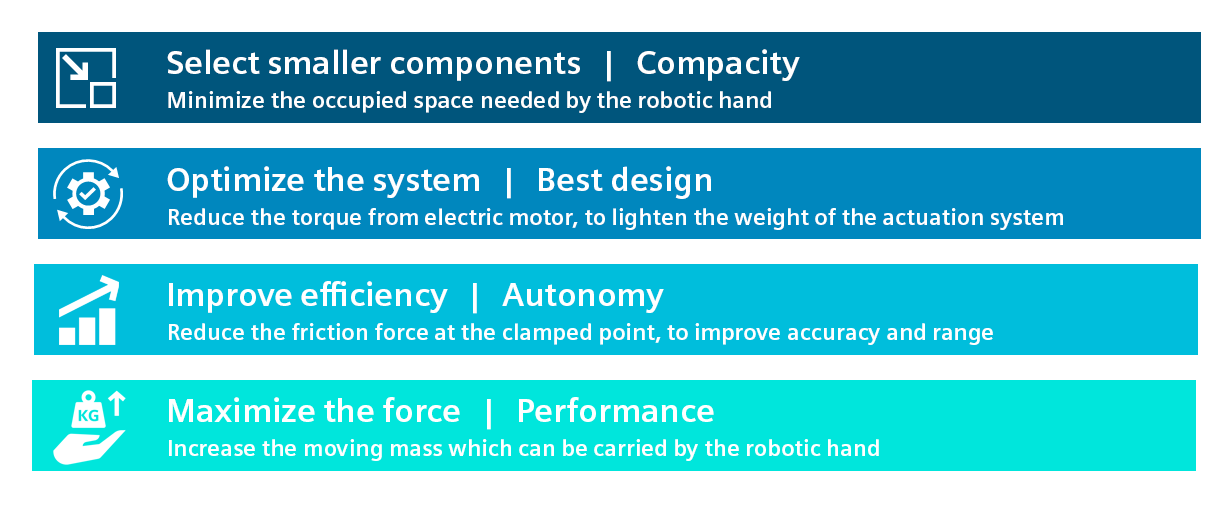
Simcenter Amesim provides the digital twin foundation to make that possible, with a single system simulation platform.
As humanoid robotics moves toward large-scale industrial adoption, system simulation is becoming much more than a design tool.
It is becoming the key enabler that transforms robotic hands from complex mechanical assemblies into optimized, production-ready systems capable of delivering human-like manipulation in the real world.
Learn more about Simcenter Amesim
Simcenter Amesim is the leading integrated, scalable system simulation platform, allowing system simulation engineers to virtually assess and optimize the performance of mechatronic systems.